Setup: adapted from the code of FluidGym (Becktepe et al., ICML 2026), where it is the uncontrolled flow of the channel flow environments
Run:python turbulent_channel_flow_sample.py from the repository root (needs the noise extension for the initial condition)
Fully developed turbulence between two parallel walls, in a small 3D channel of π × 2 × π/2 with 643 cells. The flow is periodic in the stream-wise and span-wise directions and is driven by a forcing that balances the wall shear stress. The channel flow of the paper, at Reτ = 550 with turbulence statistics and a learned SGS model, is described in Turbulent Channel Flow SGS Model.
Stream-wise velocity fluctuations u′ in the whole channel (flow from left to right), scaled by their rms value at each height (blue: slower, red: faster than the mean). Values within ±1 rms are transparent. 100 time units (about 4 eddy turnover times) after the 400 iterations of the sample. Simulated with PICT, rendered for this website with vedo.
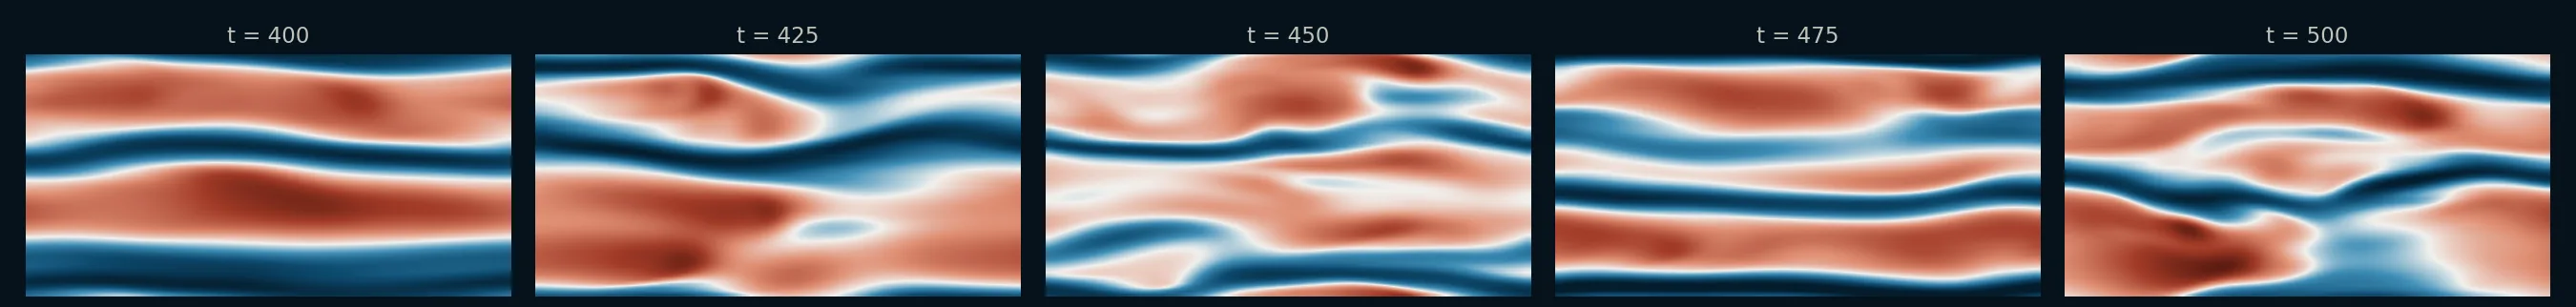
The same run in the x–z plane at y+ ≈ 14 above the lower wall: stream-wise velocity fluctuations in wall units (±6.5 uτ). The elongated low- and high-speed streaks are characteristic of wall turbulence. Simulated with PICT and rendered for this website.
Near-wall streaks at t = 400, 425, 450, 475 and 500.
Setup (default run of the sample)
Channel of π × 2 × π/2 (stream-wise × wall-normal × span-wise), walls at y = ±1, periodic in x and z
One block of 64 × 64 × 64 cells, refined towards both walls
Target friction Reynolds number Reτ = 180, with the center-line velocity and the half-height as units
Initial condition: Reichardt's mean profile with curl noise
400 iterations of 1.0 time units (ca. 17 eddy turnover times), adaptive sub-steps with a CFL number of 0.1. According to the script, the flow becomes turbulent after ca. 8 eddy turnover times.
make_y_weights places the vertices between the walls so that the cell size grows by a factor of 1.2N/2 between neighbors (N = refinement_strength, 1 by default). The 2D grid is then extruded in z:
The flow parameters follow from Reτ: TCF_tools.Re_wall_to_cl gives the center-line Reynolds number, which sets the viscosity and the friction velocity. A single block is closed in y; the other directions keep the default periodic boundaries. The initial velocity is Reichardt's law of the wall plus curl noise from the SimplexNoiseVariations extension:
dims=3delta=1Re_center=TCF_tools.Re_wall_to_cl(Re_wall)u_wall=Re_wall/Re_center# friction velocityviscosity=delta/Re_centergrid=make_channel_grid(res_x,res_y,res_z,length,depth,delta=delta,refinement_strength=refinement_strength,dtype=dtype)viscosity=torch.ones([1],dtype=dtype,device=cpu_device)*viscositydomain=PISOtorch.Domain(dims,viscosity,passiveScalarChannels=0,name="DomainChannel",device=cuda_device,dtype=dtype)# create block from the mesh on the domain (missing settings, fields and transformation metrics are created automatically)block=domain.CreateBlock(vertexCoordinates=grid.to(cuda_device).contiguous(),name="BlockChannel")# closing -y also closes +y as they are connected via the default periodic boundaryblock.CloseBoundary("-y")# initial velocity: turbulent mean profile in xvel_init=make_reichardt_profile(domain,u_wall)vel_init=vel_init.view(1,1,1,res_y,1).expand(-1,-1,res_z,-1,res_x)vel_init=torch.cat([vel_init]+[torch.zeros_like(vel_init)]*(dims-1),dim=1)ifinit_with_noise:importSimplexNoiseVariationscurl_noise=SimplexNoiseVariations.GenerateSimplexNoiseVariation([res_x,res_y,res_z],cuda_device,[2/res_x,2/res_y,2/res_z],[0]*3,SimplexNoiseVariations.NoiseVariation.CURL)curl_noise*=0.5*vel_init/torch.max(torch.linalg.vector_norm(curl_noise,dim=1))vel_init=vel_init+curl_noiseblock.setVelocity(vel_init.to(dtype).contiguous())
Without the noise extension, pass init_with_noise=False. The flow then starts from the unperturbed mean profile.
A periodic channel needs a force to replace the pressure drop of a real channel. The sample computes the mean wall shear stress from the mean velocity of the first cells next to the walls, and sets it as a uniform stream-wise velocity source before every step. The forcing thus balances the friction at the walls, which keeps the mass flow rate constant according to the script (see Velocity sources):
defmake_dynamic_forcing_fn(domain,delta:float=1):# A stream-wise velocity source that balances the mean shear stress at the walls, set before every step.# Returns the callback and a function to compute the mean wall shear stress.dims=domain.getSpatialDims()pos_y=torch.mean(domain.getBlock(0).getCellCoordinates()[0,1],dim=(0,2))wall_distance=(delta+pos_y[0].item(),delta-pos_y[-1].item())# distance of the first cell centers from the wallsdefget_wall_shear_stress(domain):block=domain.getBlock(0)mean_vel_u=torch.mean(block.velocity[0,0],dim=(0,2))# mean over x and zviscosity=domain.viscosity.to(domain.getDevice())return(viscosity*mean_vel_u[0]/wall_distance[0]+viscosity*mean_vel_u[-1]/wall_distance[1])*0.5defdynamic_forcing_fn(domain,**kwargs):G=torch.cat([get_wall_shear_stress(domain).reshape([1,1]),torch.zeros([1,dims-1],dtype=domain.getDtype(),device=domain.getDevice())],dim=1)# NCdomain.getBlock(0).setVelocitySource(G)returndynamic_forcing_fn,get_wall_shear_stress
The same wall shear stress gives the current friction Reynolds number, which the sample logs after every iteration to show whether the flow is turbulent:
deflog_fn(domain,it,**kwargs):# the friction Reynolds number from the current wall shear stress shows if the flow is turbulentLOG.info("Re_tau at %.02f ETT: %.01f",TCF_tools.t_to_ETT(it*time_step,u_wall),np.sqrt(get_wall_shear_stress(domain).item())/viscosity)
In the run for the video, this value stayed between 173 and 192 (mean 183).
The advection uses BiCGStab with a tolerance of 10−6. The adaptive time stepping uses a small CFL number: according to the script, higher values can result in a laminar flow. Before the projection of the initial field, the sample calls CopyVelocityResultFromBlocks, which copies the block velocities into the domain's global velocity result buffer:
sim=PISOtorch_simulation.Simulation(domain=domain,prep_fn=prep_fn,substeps="ADAPTIVE",adaptive_CFL=adaptive_CFL,time_step=time_step,corrector_steps=2,advection_use_BiCG=True,advection_tol=1e-6,pressure_tol=1e-6,advect_non_ortho_steps=1,pressure_non_ortho_steps=1,pressure_return_best_result=True,velocity_corrector="FD",non_orthogonal=True,log_interval=1,norm_vel=True,log_fn=log_fn,output_resampling_shape=resample_shape,output_resampling_fill_max_steps=resample_fill_steps,log_dir=log_dir,save_domain_name="domain",stop_fn=STOP_FN)sim.preconditionBiCG=Falsesim.BiCG_precondition_fallback=Trueifnotload_domain_path:# make the initial velocity divergence-freePISOtorch.CopyVelocityResultFromBlocks(domain)sim.make_divergence_free()
The transition to turbulence takes a while, so a run can continue from the saved domain of an earlier one with load_domain_path. The script also contains a commented run of the large channel (2π × 2 × π, 128 × 64 × 128 cells), as in the large channel flow environments of FluidGym:
# small channel (pi x 2 x pi/2) at Re_tau=180, 400 iterations are ca. 17 ETTturbulent_channel_flow_sample(run_dir,name="Re180_small",res_x=64,res_y=64,res_z=64,length=np.pi,depth=np.pi/2,Re_wall=180,iterations=400,time_step=1.0,dp=False,STOP_FN=stop_handler)# continue a previous simulation, e.g. after a warm-up#turbulent_channel_flow_sample(run_dir, name="Re180_small_continued", Re_wall=180, load_domain_path="./test_runs/<run_dir>/0000_channel_flow_Re180_small/domain",# iterations=200, time_step=1.0, dp=False, STOP_FN=stop_handler)# large channel (2pi x 2 x pi) at Re_tau=180, as in the large channel flow environments of FluidGym#turbulent_channel_flow_sample(run_dir, name="Re180_large", res_x=128, res_y=64, res_z=128, length=2*np.pi, depth=np.pi, Re_wall=180,# iterations=400, time_step=1.0, dp=False, STOP_FN=stop_handler)
The sample ran its default 400 iterations (t = 0 to 400). scripts/sim_flow_examples.py tcf then continued from its saved final domain with the same setup and solver settings, but with an output time step of 0.25 for a smooth video: 400 iterations, t = 400 to 500. After every iteration, a log callback recorded the stream-wise velocity in an x–z plane near the wall and in the whole channel. scripts/render_flow_examples.py renders the plane. scripts/render_tcf3d.py interpolates the 3D field to a uniform grid and ray-casts it with vedo: the color and the opacity show u′ divided by its rms value at each height over the run.